Asimov 1
A humanoid robot for locomotion and whole-body control research.
An open-source biped robot for learning and experimenting with reinforcement learning
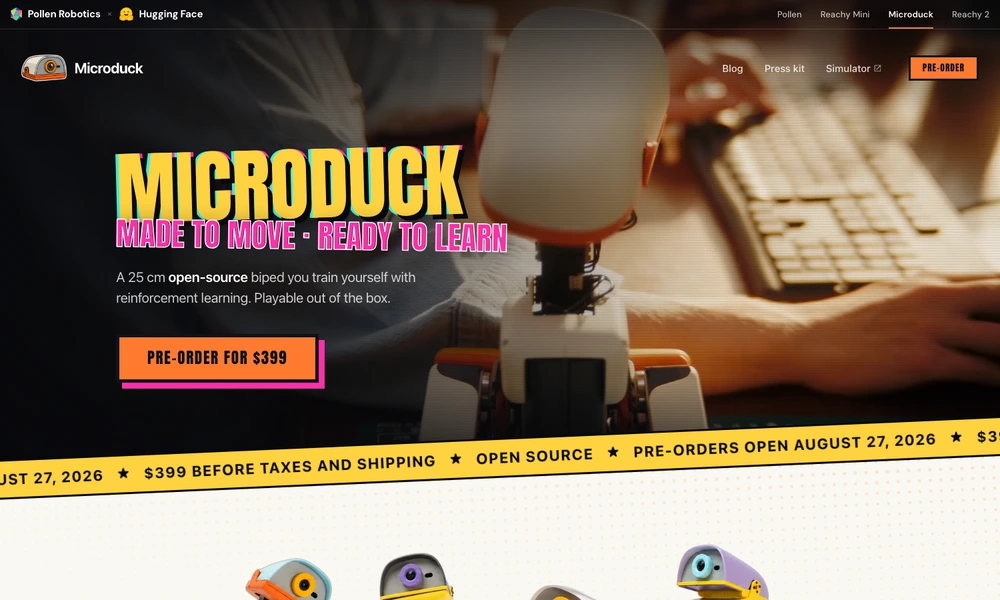
Microduck is a compact biped robot designed for hands-on experimentation with reinforcement learning. Its published software stack includes an SDK, simulation environment, and training tools, allowing builders to inspect existing behaviors, retrain policies, and deploy them to the robot. The workflow starts in a physics simulation and can continue through repeated testing on the physical machine.
The robot is designed around a 25-centimeter body with motors, a camera, LiDAR, and motion sensors. Demonstrated behaviors include walking, sitting, getting back up, and movement with optional accessories. The official site currently offers preorders, so buyers should check fulfillment details separately. The open software and retrainable policies make it relevant to robotics learners and makers.
Tried it? Share a useful thought or ask a question.
Good conversations start with a hello.
Sign in to commentA humanoid robot for locomotion and whole-body control research.
Robots and software for industrial automation
General-purpose humanoid robots for everyday physical tasks
Plan, simulate, and run repeatable robotic inspection workflows.
Operate and monitor robots with human intervention when needed
Develop robotics projects with compact arms, mobile platforms and related tools